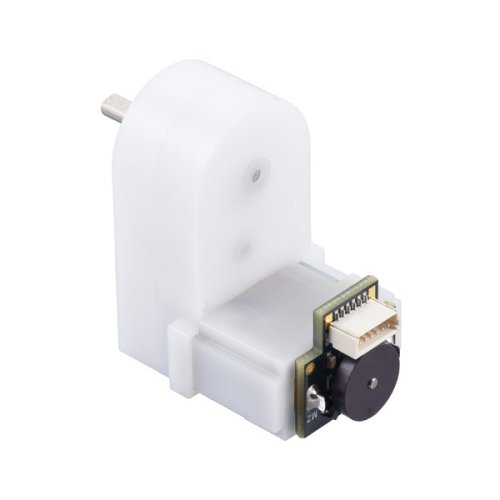
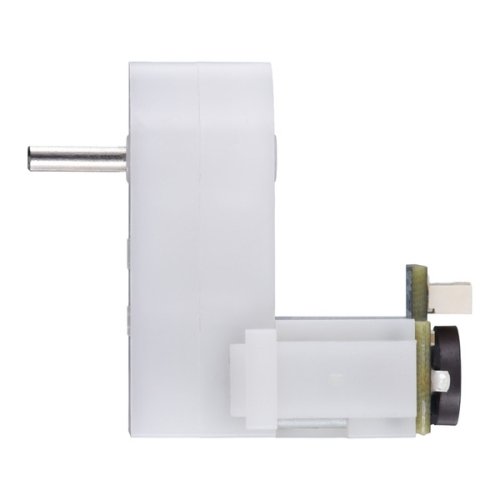
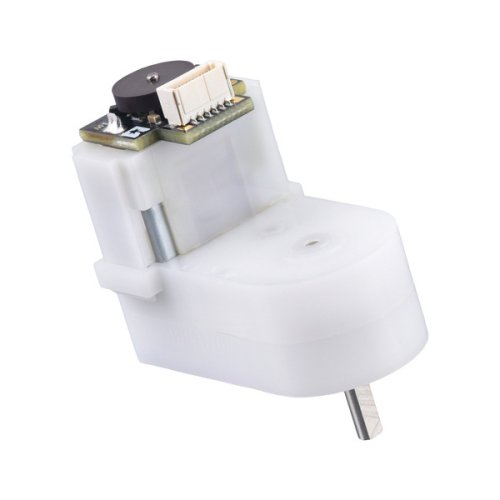
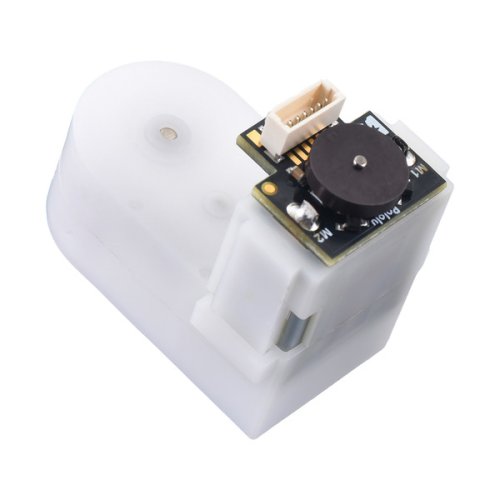
This small gearmotor features a brushed DC motor with a 120:1 plastic gearbox and a quadrature encoder with back connector (cables sold separately). While intended for operation at 4.5 V, it runs comfortably in the 3 V to 6 V range. The gearbox has a 9.7 mm long, 3 mm diameter D-shaped output shaft, and a built-in safety clutch helps protect the gears from excessive loads.
This product is an item #1520 plastic gearmotor (which is the same gearmotor included with our Romi Chassis Kits) with an item #3546 quadrature encoder installed. The encoder senses the rotation of the magnetic disc and provides a resolution of 12 counts per revolution of the motor shaft when counting both edges of both channels, which is corresponds to approximately 1,437 counts per revolution of the gearbox output shaft (i.e., 12 times the gear ratio). The encoder solution fits within the 11.5 mm × 22.5 mm cross section of the motors on three of the four sides, and it extends approximately 5.5 mm past the edge of the fourth side.
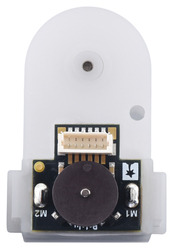
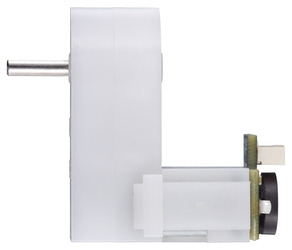
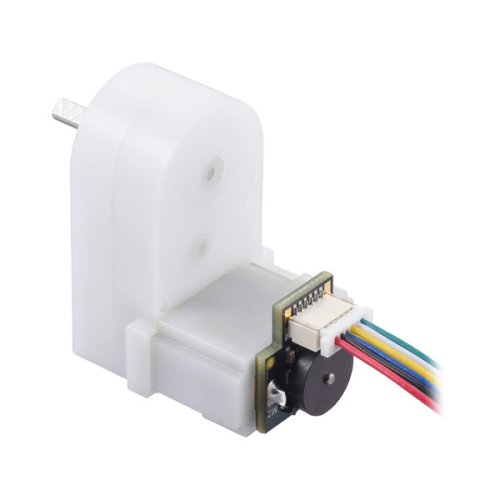
The encoder features a top-entry, 6-pin male JST SH-type connector with a 1mm pitch that is compatible with our 6-pin JST SH-type cables. When mounted on the gearmotor, we refer to it as a back-entry connector since the cable plugs straight into the back of the motor along the same axis as the motor and gearbox shafts. We also carry a version this gearmotor assembled with a side-entry encoder; the following pictures show a comparison of this back-entry (left) version and the side-entry (right) version:
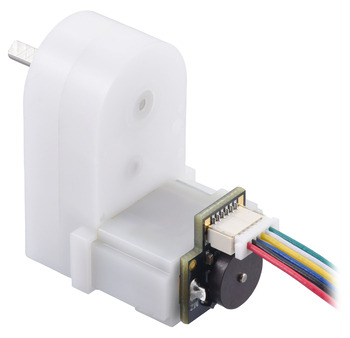
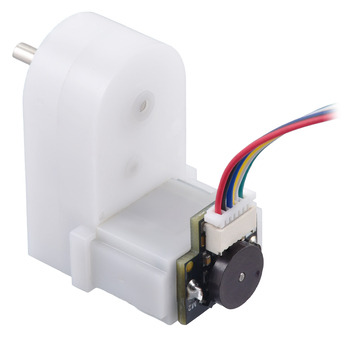
120:1 Mini Plastic Gearmotor HP, Offset 120:1 Mini Plastic Gearmotor HP, Offset
3mm D-Shaft Output, with 12 CPR Encoder, 3mm D-Shaft Output, with 12 CPR Encoder,
Back Connector (cable not included). Side Connector (cable not included).
The gearmotor consists of a brushed DC motor with a 120:1 plastic gearbox and a 9.7 mm long, 3 mm diameter “D”-shaped output shaft that is offset from but parallel to the motor shaft. It is intended for use at 4.5 V, though in general, these kinds of motors can run at voltages above and below this nominal voltage, so they should operate comfortably in the 3 V to 6 V range (rotation can start at voltages as low as 0.5 V). Lower voltages might not be practical, and higher voltages could start negatively affecting the life of the motor. The plastic gearbox is protected by a built-in safety clutch that will typically slip before the gear teeth can shear (typically when the load exceeds around 25 oz-in, or 2 kg-cm). Here are the key specifications for the gearmotor at 4.5 V:
voltage : no-load performance : stall extrapolation
4.5 V : 150 RPM, 130 mA : 1.8 kg⋅cm (25 oz⋅in), 1.25 A
Exact gear ratio: 22×38×44×26×3010×11×11×22×9≈119.76
Cable options:
We have two types of cables with matching JST SH-style connectors that can be used with this gearmotor. Single-ended versions have a connector on one end and unterminated wires on the other, while double-ended cables have twisted wires with female connectors on both ends.
Pinout:
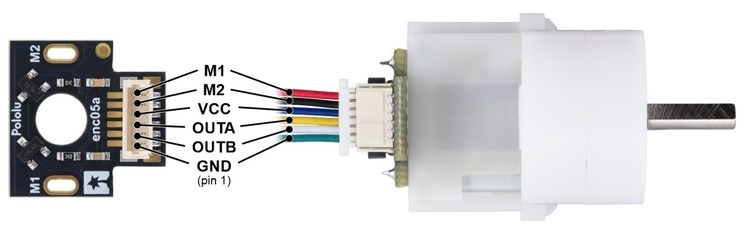
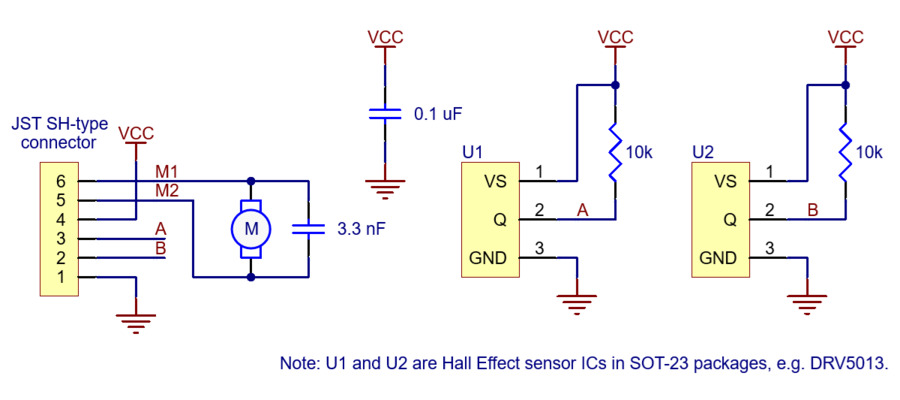
The motor leads are connected to the M1 and M2 connector pins as labeled below, and they can be accessed via the red and black wires when used with our corresponding JST cables. The remaining four connector pins are used to power the sensors and access the two quadrature outputs:
- Pin : Wire color : Function
- 1 : Green : encoder GND
- 2 : White : encoder channel B output
- 3 : Yellow : encoder channel A output
- 4 : Blue : encoder Vcc (2.7 V to 18 V)
- 5 : Black : motor power M2
- 6 : Red : motor power M1
Pololu 3548/3549 120:1 Mini Plastic Gearmotor HP, Offset 3mm D-Shaft Output, with 12 CPR Encoder, Back/Side Connector
- Brand:: Pololu
- Product Code: :Pololu-3548-3549-120:1
- Reward Points: :13
- Availability: :In Stock
-
रo 1,342.00
- Price in reward points: 1342
-
- 25 or more रo 1,283.00
- 100 or more रo 1,236.00
- 250 or more रo 1,191.00
- 500 or more रo 1,167.00
Available Options
Related Products
Pololu 1516 / 1520 120:1 Mini Plastic Gearmotor, Offset 3mm D-Shaft Output, Extended Motor Shaft
These brushed DC gearmotors are compact and affordable — perfect for building a quick, miniature rob..
रo 826.53
Tags: Pololu, 120:1, Mini, Plastic Gearmotor, HP, Offset, D-Shaft, Output, 12 CPR, Encoder